NVIDIA releases Isaac ROS 5.0
NVIDIA has released Isaac ROS 5.0, extending its robotics software with agent-ready workflows and accelerated perception. The package is aimed at developers building robot applications with ROS and NVIDIA hardware.
Reusable skills join the robotics toolchain
The Isaac ROS release adds support for ROS Lyrical and Ubuntu 24.04, plus setup and manipulation skills that people and agents can reuse. It also describes agent-ready documentation and deployment across the Jetson platform.
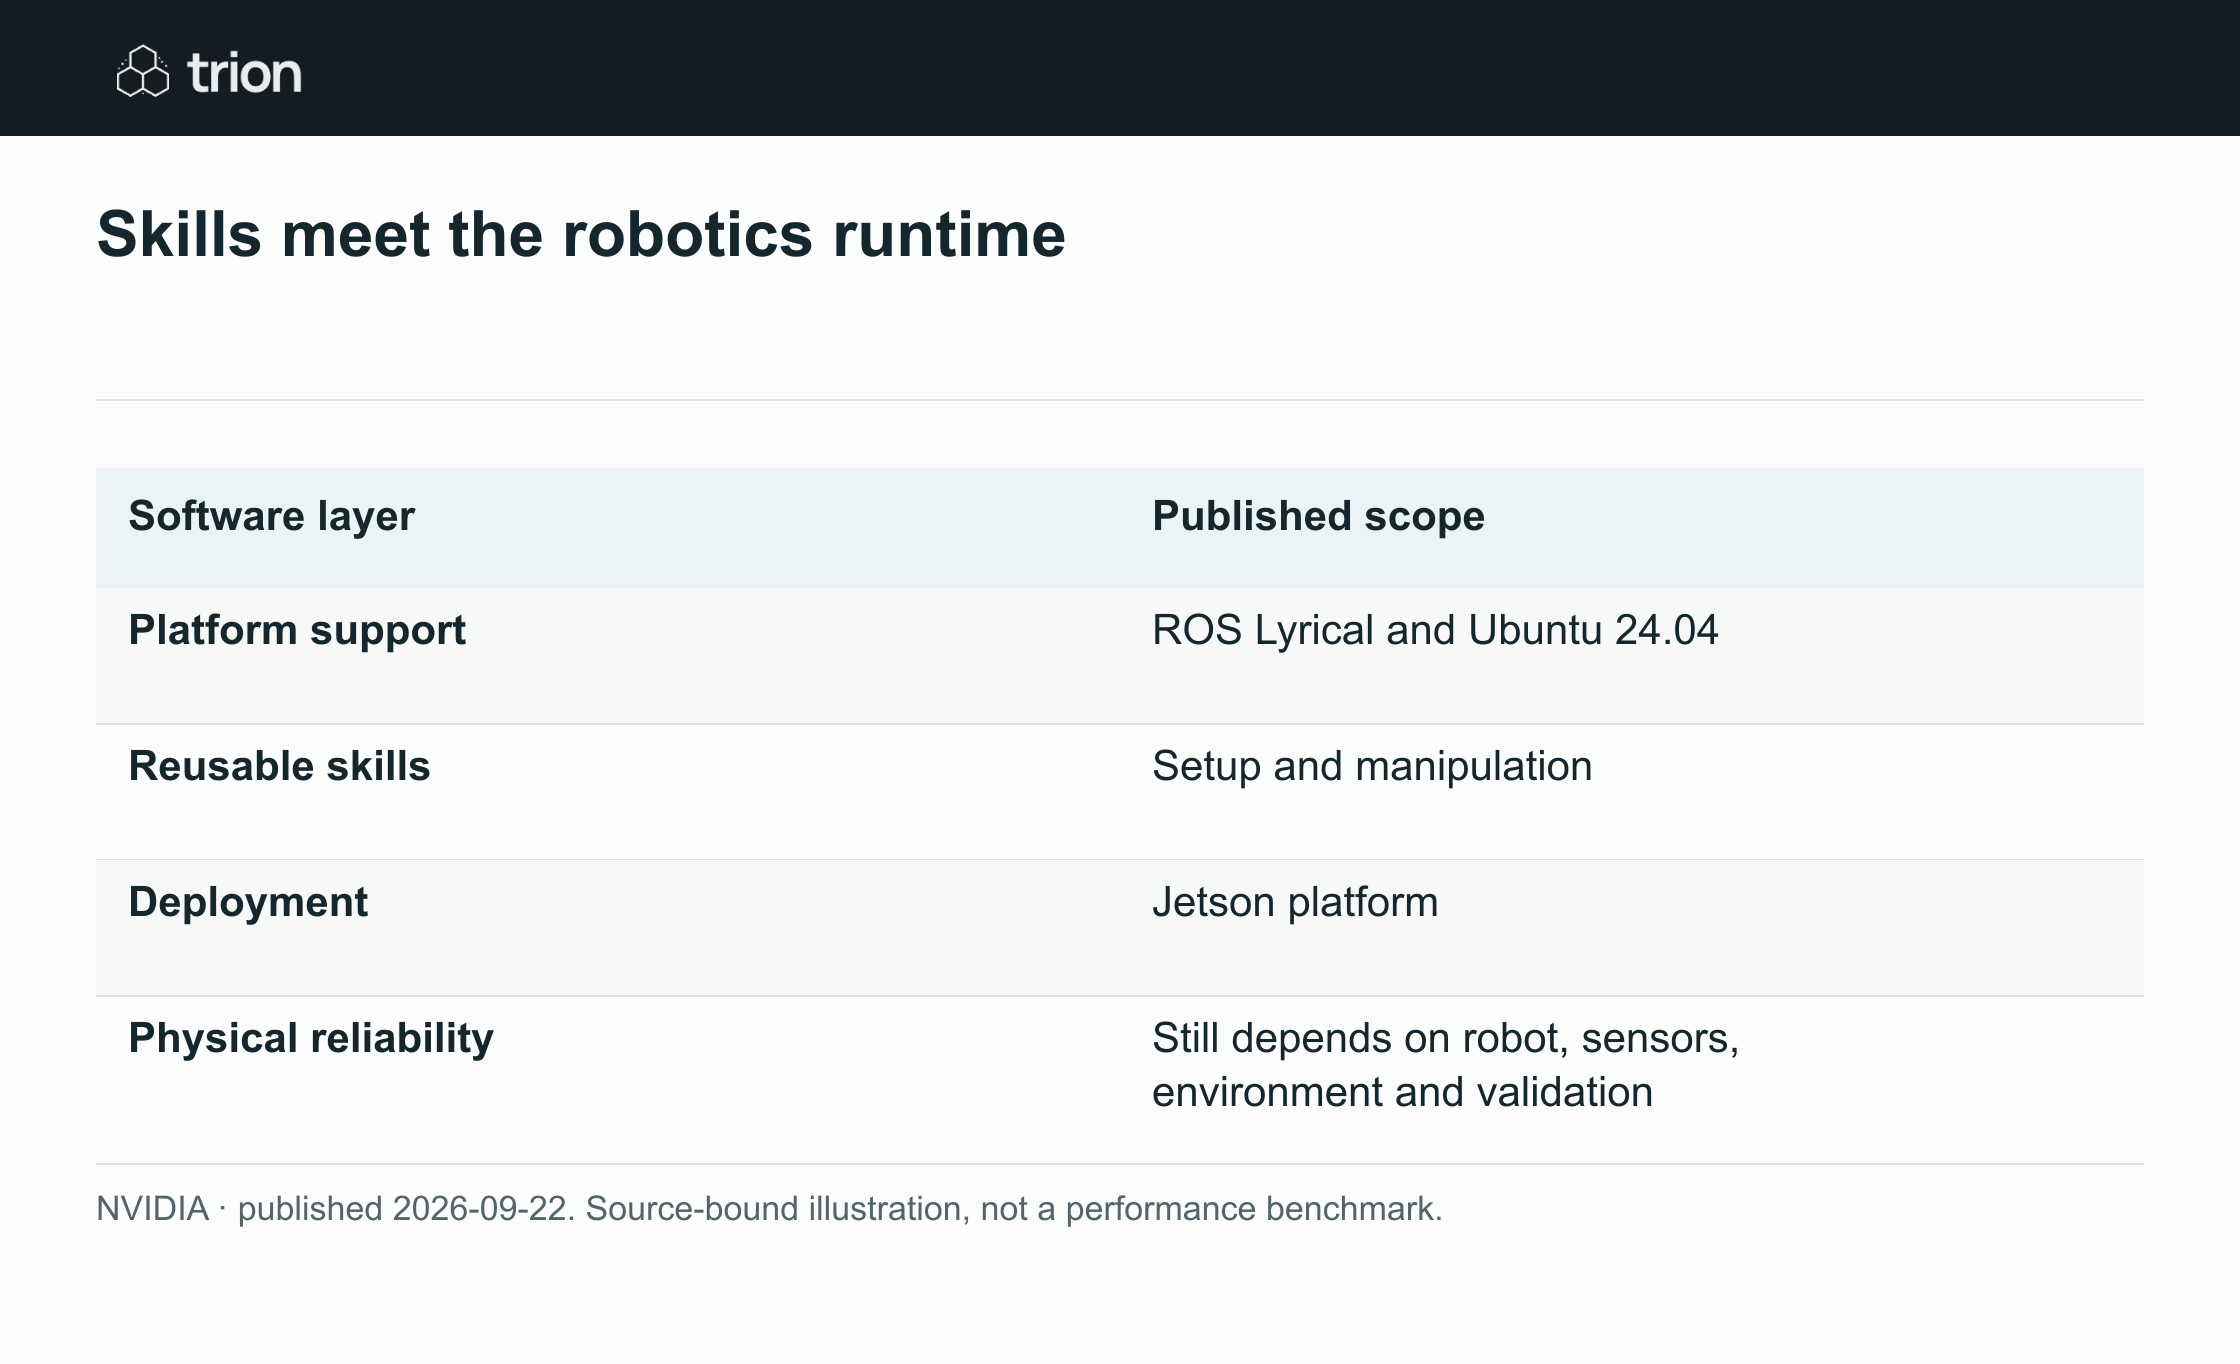
Skills meet the robotics runtime
- Platform support
- ROS Lyrical and Ubuntu 24.04
- Reusable skills
- Setup and manipulation
- Deployment
- Jetson platform
- Physical reliability
- Still depends on robot, sensors, environment and validation
View data
| Software layer | Published scope |
|---|---|
| Platform support | ROS Lyrical and Ubuntu 24.04 |
| Reusable skills | Setup and manipulation |
| Deployment | Jetson platform |
| Physical reliability | Still depends on robot, sensors, environment and validation |
NVIDIA · published 2026-09-22. Source-bound illustration, not a performance benchmark.
Download imageIsaac ROS is a collection of accelerated software packages, rather than a finished general-purpose robot. A working deployment still depends on the robot, sensors, environment and validation around its actions. Software support for a workflow does not establish that a physical task is safe or reliable in every setting.
Original sources
- NVIDIA: original announcementblogs.nvidia.com
Checked 9 Oct 2026 · A manually curated edition. Availability may change; company performance claims are not Trion test results. Editorial method.